Seoul National University

Hansol Ryu

Mechanical Engineering & Computer Science

I am a senior undergraduate student in Mechanical Engineering and Computer Science at Seoul National University. I am currently an undergraduate researcher in the Scalable Robot Learning Lab with Prof. Youngwoon Lee.

I conducted my B.S. thesis research in the Robotics Laboratory with Prof. Frank C. Park. Previously, I worked on robot perception for tabletop cluttered scenes in the RPM Robotics Lab with Prof. Ayoung Kim.

I am interested in robot learning, particularly in developing scalable and data-efficient methods for learning complex robotic behaviors. I am especially interested in leveraging structural and physical inductive biases, including insights from control and dynamics, to improve how robots learn and physically interact with their environments. My interests also extend to deep reinforcement learning and computer vision for increasingly dexterous and general robotic systems.

Hansol Ryu

Selected Research

Scalable Robot Learning

Scalable Robot Learning Lab · Seoul National University

Robot Learning for Dexterous and Generalizable Manipulation

Undergraduate Researcher · Prof. Youngwoon Lee · 2026–Present

I am currently working on robot learning for dexterous manipulation, with interests in scalable policy learning, reinforcement learning, and reliable deployment of learned robotic behaviors.

My current work involves studying learning and optimization methods for complex manipulation behaviors and exploring how robotic systems can improve through data and physical interaction.
Robot Learning Reinforcement Learning Dexterous Manipulation Policy Learning
B.S. Thesis

Robotics Laboratory · Seoul National University

Geometric Visuomotor Learning for Contact-Rich Manipulation

B.S. Thesis Research · Prof. Frank C. Park · 2026

I studied how geometric representations and feedback mechanisms could improve the robustness and spatial generalization of learned visuomotor policies for contact-rich manipulation.

I developed simulation and evaluation pipelines to compare policy representations under spatial transformations and investigated how learned visuomotor policies could be combined with force feedback and compliant low-level robot control.

Robot Learning Visuomotor Policy Geometric Learning Robot Control
Perception and spatial reasoning for post-grasp retrieval in clutter

RPM Robotics Lab · Seoul National University

Perception and Spatial Reasoning for Post-Grasp Retrieval in Clutter

Undergraduate Research · Prof. Ayoung Kim · 2026

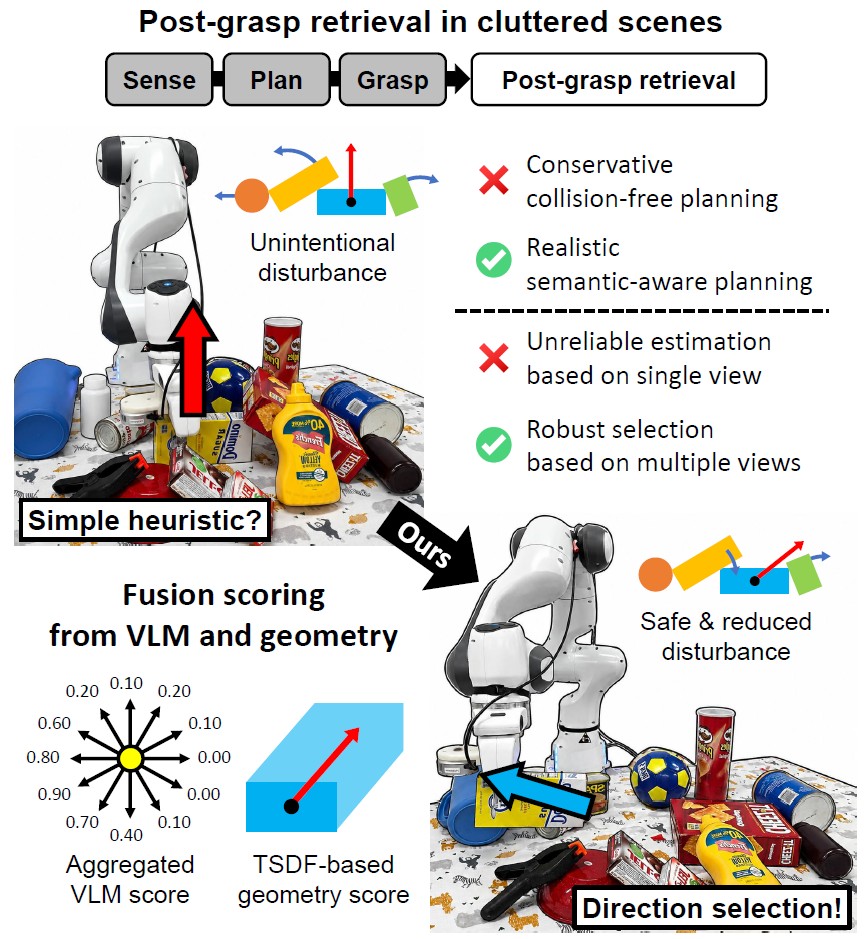
I worked on perception and spatial reasoning for post-grasp retrieval in cluttered tabletop scenes, where a robot must extract a target object while minimizing disturbance to surrounding objects.

My work included implementing and evaluating a TSDF-based active perception baseline, exploring TSDF and 3D Gaussian Splatting for 3D scene representation, developing a VLM-based pipeline for reasoning about retrieval directions from visual observations, and building the real-robot evaluation pipeline and quantitative metrics for measuring clutter disturbance.

Robot Perception Active Perception Vision-Language Models 3D Representation

Publications

Post-Grasp Retrieval in Cluttered Scenes via Zero-Shot VLM-Guided Spatial Reasoning and Active Perception

S. H. Jeong, M. Kim, H. Ryu, J. Noh, and A. Kim

IEEE Robotics and Automation Letters (RA-L), under review, 2026

Selected Projects

Interactive and Networked Robotics Laboratory · Seoul National University

Contact Dynamics Simulation with Cascaded Newton-Augmented Lagrangian Methods

Developed a MATLAB simulator for rigid-body contact dynamics using cascaded Newton-based augmented-Lagrangian numerical methods. The project investigated numerical formulations for resolving unilateral contact constraints and provided a simulation testbed for studying physically grounded robot dynamics and control.

Contact Dynamics Numerical Optimization Robot Dynamics MATLAB
View Project →

SNU Mechatronics Design

Circa — Noninvasive Sleep Monitoring and Environment-Adaptive IoT Hub

Developed a contactless sleep-monitoring system using an 8 × 8 time-of-flight LiDAR array and multimodal environmental sensors. The system combined noninvasive bedside sensing with environment-aware IoT functionality for monitoring sleep and surrounding conditions.

1st Place · SNU Mechatronics Design Competition

Mechatronics ToF LiDAR Embedded Systems IoT
View Project →

Education

Seoul National University

B.S. Candidate in Mechanical Engineering

B.S. Candidate in Computer Science and Engineering

Seoul, Korea